Lee, J., Hwangbo, J., Wellhausen, L., Koltun, V. & Hutter, M. Learning quadrupedal locomotion over challenging terrain. Sci. Robot. 5, eabc5986 (2020). Article PubMed Google Scholar McGeer, T. Dynamic walking robots and the w prize [industry/research news]. IEEE Robot. Autom. Mag. 14, 13–15 (2007). Article Google Scholar Shin, Y.-H. et al. Design of KAIST HOUND,
Turbulent fluid flow is a persistent challenge in physics and engineering: it disrupts aviation and reduces the efficiency of wind turbines. In the body, disturbed blood flow can even contribute to problems in the circulatory system. Turbulence is also complex and unpredictable, so devising strategies to control it is notoriously difficult. Now, writing in Nature,
Shimamoto, D. S., Shimamoto, K., Mahmoudi, S. & Poincloux, S. Phys. Rev. X 16, 031006 (2026). Article Google Scholar Singal, K. et al. Nature Commun. 15, 2622 (2024). Article PubMed Google Scholar Spencer, D. J. Knitting Technology: A Comprehensive Handbook and Practical Guide 3rd edn (CRC Press, 2001). Google Scholar Sanchez, V. et al. Adv.
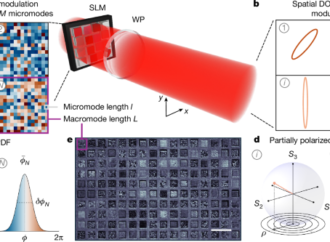
Experimental set-up The set-up consists of the spatial DOP modulator interfaced separately with the high-dimensional PNN and the encryption–decryption system. These two blocks make a different use of scattering media and digital neural networks and are described hereafter in dedicated subsections. The DOP modulator is composed of a phase-only liquid-crystal-on-silicon SLM (Hamamatsu X13138, 1,280 × 1,024 pixels, 12.5 μm