Lee, J., Hwangbo, J., Wellhausen, L., Koltun, V. & Hutter, M. Learning quadrupedal locomotion over challenging terrain. Sci. Robot. 5, eabc5986 (2020). Article PubMed Google Scholar McGeer, T. Dynamic walking robots and the w prize [industry/research news]. IEEE Robot. Autom. Mag. 14, 13–15 (2007). Article Google Scholar Shin, Y.-H. et al. Design of KAIST HOUND,
Lee, J., Hwangbo, J., Wellhausen, L., Koltun, V. & Hutter, M. Learning quadrupedal locomotion over challenging terrain. Sci. Robot. 5, eabc5986 (2020).
Google Scholar
McGeer, T. Dynamic walking robots and the w prize [industry/research news]. IEEE Robot. Autom. Mag. 14, 13–15 (2007).
Google Scholar
Shin, Y.-H. et al. Design of KAIST HOUND, a quadruped robot platform for fast and efficient locomotion with mixed-integer nonlinear optimization of a gear train. In Proc. 2022 International Conference on Robotics and Automation (ICRA) 6614–6620 (IEEE, 2022).
Bjelonic, F. et al. Learning-based design and control for quadrupedal robots with parallel-elastic actuators. IEEE Robot. Autom. Lett. 8, 1611–1618 (2023).
Google Scholar
Fu, Z., Kumar, A., Malik, J. & Pathak, D. Minimizing energy consumption leads to the emergence of gaits in legged robots. In Proc. 5th Conference on Robot Learning (eds Faust, A., Hsu, D. & Neumann, G.) 928–937 (PMLR, 2022).
Yang, Y., Zhang, T., Coumans, E., Tan, J. & Boots, B. Fast and efficient locomotion via learned gait transitions. In Proc. 5th Conference on Robot Learning (eds Faust, A., Hsu, D. & Neumann, G.) 773–783 (PMLR, 2022).
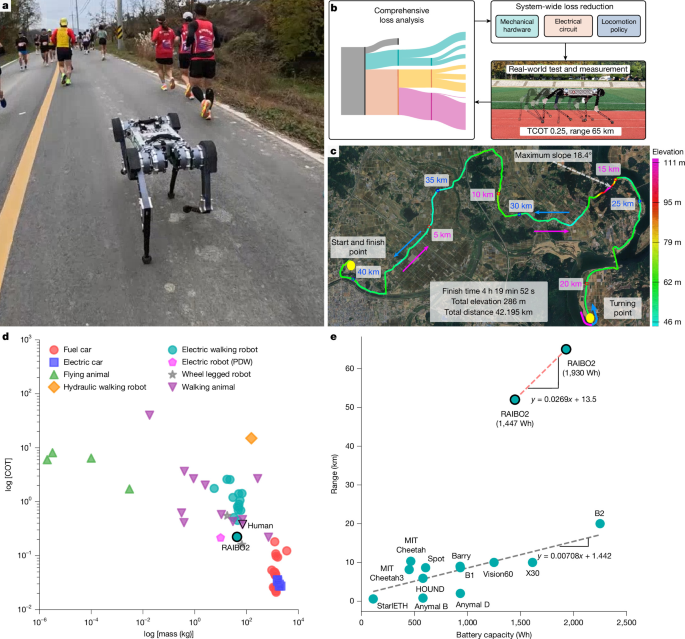
RaiLab KAIST. (1x speed) raibo2 completes full marathon (42.195km) in 4:19:52—world’s first robot marathon record. YouTube https://youtu.be/-HMFoa3g9nA (2024).
Park, H.-W., Wensing, P. M. & Kim, S. High-speed bounding with the MIT Cheetah 2: control design and experiments. Int. J. Robot. Res. 36, 167–192 (2017).
Google Scholar
Jin, Y., Liu, X., Shao, Y., Wang, H. & Yang, W. High-speed quadrupedal locomotion by imitation-relaxation reinforcement learning. Nat. Mach. Intell. 4, 1198–1208 (2022).
Google Scholar
Ji, G., Mun, J., Kim, H. & Hwangbo, J. Concurrent training of a control policy and a state estimator for dynamic and robust legged locomotion. IEEE Robot. Autom. Lett. 7, 4630–4637 (2022).
Google Scholar
Shin, Y.-H. et al. Reinforcement learning for high-speed quadrupedal locomotion with motor operating region constraints: mitigating motor model discrepancies through torque clipping in realistic motor operating region. IEEE Robot. Autom. Mag. 32, 49–59 (2024).
Google Scholar
Choi, S. et al. Learning quadrupedal locomotion on deformable terrain. Sci. Robot. 8, eade2256 (2023).
Google Scholar
Miki, T. et al. Learning robust perceptive locomotion for quadrupedal robots in the wild. Sci. Robot. 7, eabk2822 (2022).
Google Scholar
Kim, H. et al. High-speed control and navigation for quadrupedal robots on complex and discrete terrain. Sci. Robot. 10, eads6192 (2025).
Google Scholar
Unitree B2: go beyond the limits. Unitree Robotics https://www.unitree.com/b2 (2023).
Wensing, P. M. et al. Proprioceptive actuator design in the MIT Cheetah: impact mitigation and high-bandwidth physical interaction for dynamic legged robots. IEEE Trans. Robot. 33, 509–522 (2017).
Google Scholar
Seok, S. et al. Design principles for energy-efficient legged locomotion and implementation on the MIT Cheetah robot. IEEE/ASME Trans. Mechatronics 20, 1117–1129 (2015).
Google Scholar
Kitano, S., Hirose, S., Horigome, A. & Endo, G. TITAN-XIII: sprawling-type quadruped robot with ability of fast and energy-efficient walking. ROBOMECH J. 3, 1–16 (2016).
Google Scholar
Valsecchi, G. et al. Barry: a high-payload and agile quadruped robot. IEEE Robot. Autom. Lett. 8, 6939–6946 (2023).
Google Scholar
Chen, L. et al. Optimized foothold planning and posture searching for energy-efficient quadruped locomotion over challenging terrains. In Proc. 2020 IEEE International Conference on Robotics and Automation (ICRA) 399–405 (IEEE, 2020).
22nd Sangju Gotgam Marathon record system. SPCT Co. https://time.spct.kr/m2.php?EVENT_NO=20241117017&TargetYear=2024¤tPage=1&BIB_NO=042004 (2024).
Tucker, V. A. The energetic cost of moving about: walking and running are extremely inefficient forms of locomotion. Much greater efficiency is achieved by birds, fish—and bicyclists. Am. Sci. 63, 413–419 (1975).
Google Scholar
Bledt, G. et al. MIT Cheetah 3: design and control of a robust, dynamic quadruped robot. In Proc. 2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2245–2252 (IEEE, 2018).
Katz, B., Di Carlo, J. & Kim, S. Mini Cheetah: a platform for pushing the limits of dynamic quadruped control. In Proc. 2019 International Conference on Robotics and Automation (ICRA) 6295–6301 (IEEE, 2019).
Chang, L., Jeng, Y.-R. & Huang, P.-Y. Modeling and analysis of the meshing losses of involute spur gears in high-speed and high-load conditions. J. Tribol. 135, 011504 (2013).
Google Scholar
Margaria, R. Positive and negative work performances and their efficiencies in human locomotion. Int. Z. Angew. Physiol. 25, 339–351 (1968).
Google Scholar
Hutter, M. et al. Starleth: a compliant quadruped robot for fast, efficient, and versatile locomotion. In Adaptive Mobile Robotics (eds Azad, A. K. M., Cowan, N. J., Tokhi, M. O., Virk, G. S. & Eastman, R. D.) 483–490 (World Scientific, 2012).
Ding, L. et al. Brief analysis of a Big-Dog quadruped robot. Chin. Mech. Eng. 23, 505–514 (2012).
Li, M. et al. Leg prototype of a bio-inspired quadruped robot. Robot 36, 21–28 (2014).
Google Scholar
Shi, Y., Zhang, M. & Zhang, X. Design and analysis of quadruped robot’s leg with flexible joints. J. Huazhong Univ. Sci. Technol. (Nat. Sci. Ed.) 45, 17–22 (2017).
Mi, C., Slemon, G. & Bonert, R. Modeling of iron losses of permanent-magnet synchronous motors. IEEE Trans. Ind. Appl. 39, 734–742 (2003).
Google Scholar
Lakkas, G. MOSFET power losses and how they affect power-supply efficiency. Analog Applications J. 1Q, SLYT664 (Texas Instruments, 2016).
Gopalan, A. Calculating Power Dissipation for a H-bridge or Half Bridge Driver Technical Report SLVA504A (Texas Instruments, 2021).
Bobbert, A. C. Energy expenditure in level and grade walking. J. Appl. Physiol. 15, 1015–1021 (1960).
Google Scholar
Tucker, V. A. Energetic cost of locomotion in animals. Comp. Biochem. Physiol. 34, 841–846 (1970).
Google Scholar
EV Database. Compare electric vehicles https://ev-database.org/ (EV Database.org, 2025).
Fuelly. Track and compare your mpg https://www.fuelly.com/car (Fuelly, 2026).
McGeer, T. Passive dynamic walking. Int. J. Robot. Res. 9, 62–82 (1990).
Google Scholar
Bhounsule, P. et al. Low-bandwidth reflex-based control for lower power walking: 65 km on a single battery charge. Int. J. Robot. Res. 33, 1305–1321 (2014).
Google Scholar
Li, Q., Liu, G., Tang, J. & Zhang, J. A simple 2D straight-leg passive dynamic walking model without foot-scuffing problem. In Proc. 2016 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 5155–5161 (IEEE, 2016).
Lee, J. et al. Learning robust autonomous navigation and locomotion for wheeled-legged robots. Sci. Robot. 9, eadi9641 (2024).
Google Scholar
Hutter, M. et al. Anymal—toward legged robots for harsh environments. Adv. Robot. 31, 918–931 (2017).
Google Scholar
Boston Dynamics. Spot – the agile mobile robot. Boston Dynamics https://bostondynamics.com/products/spot/ (2019).
Unitree B1: Land Overlord. Unitree https://www.unitree.com/b1 (2022).
Meet ANYmal your new inspector. ANYbotics https://www.anybotics.com/robotics/anymal/ (2021).
Vision 60: Agile and autonomous quadruped. Ghost Robotics https://www.ghostrobotics.io/vision-60 (2021).
X30: Industrial application quadruped robot. DEEP Robotics https://deeprobotics.cn/en/index/product3.html (2023).
Hartley, R., Ghaffari, M., Eustice, R. M. & Grizzle, J. W. Contact-aided invariant extended Kalman filtering for robot state estimation. Int. J. Robot. Res. 39, 402–430 (2020).
Google Scholar
Raibert, M. H. & Tello, E. R. Legged robots that balance. IEEE Expert 1, 89 (1986).
Google Scholar
American Gear Manufacturers Association. Fundamental Rating Factors and Calculation Methods for Involute Spur and Helical Gear Teeth. ANSI/AGMA 2101-D04 (American Gear Manufacturers Association, 2004).
Infineon Technologies AG. EiceDRIVER high voltage gate driver IC evaluation board. Application Note EVAL_6EDL04N02PR, Rev. 1.0 (Infineon Technologies AG, 2013).
Schulman, J., Wolski, F., Dhariwal, P., Radford, A. & Klimov, O. Proximal policy optimization algorithms. Preprint at https://arxiv.org/abs/1707.06347 (2017).
Pinto, L., Andrychowicz, M., Welinder, P., Zaremba, W. & Abbeel, P. Asymmetric actor critic for image-based robot learning. Preprint at https://arxiv.org/abs/1710.06542 (2017).
Hwangbo, J., Lee, J. & Hutter, M. Per-contact iteration method for solving contact dynamics. IEEE Robot. Autom. Lett. 3, 895–902 (2018).
Google Scholar
Bengio, Y., Louradour, J., Collobert, R. & Weston, J. Curriculum learning. In Proc. 26th Annual International Conference on Machine Learning (eds Bottou, L. & Littman, M.) 41–48 (ACM, 2009).
Mysore, S., Mabsout, B., Mancuso, R. & Saenko, K. Regularizing action policies for smooth control with reinforcement learning. In Proc. 2021 IEEE International Conference on Robotics and Automation (ICRA) 1810–1816 (IEEE, 2021).
Peng, X. B., Andrychowicz, M., Zaremba, W. & Abbeel, P. Sim-to-real transfer of robotic control with dynamics randomization. In Proc. 2018 IEEE International Conference on Robotics and Automation (ICRA) 3803–3810 (IEEE, 2018).
EtherCAT – the Ethernet fieldbus. EtherCAT Technology Group https://www.ethercat.org/default.htm (2024).
Tong, W., Wu, S., Sun, J. & Zhu, L. Iron loss analysis of permanent magnet synchronous motor with an amorphous stator core. In Proc. 2016 IEEE Vehicle Power and Propulsion Conference (VPPC) 1–6 (IEEE, 2016).
Bertotti, G. General properties of power losses in soft ferromagnetic materials. IEEE Trans. Magn. 24, 621–630 (1988).
Google Scholar
Lee, C. Dataset for ‘RAIBO2: highly efficient quadruped robot completing full marathon with a single battery charge’. Zenodo https://doi.org/10.5281/zenodo.14825866 (2025).
Keep following us for the latest insights.